FORUM TOPIC · READ ONLY
IMU Complementary filter method
IMU Complementary filter method
Forum : General Remark and Questions
4 message(s) · archive en lecture seule
hi,
I am new to this.
I'm evaluating that method adopted to generate the artificial horizon.
regarding the procedure of complementary filters for mixing Gyro and accelerometer, I see no way that prevents the spurious signals produced by the accelerations in typical flight.
In http://www.kerhuel.eu/wiki/Image:IMU_Si ... Filter.png
I can see that an input acceleration will produce a change in the angle output.
I'm correct..?
I am new to this.
I'm evaluating that method adopted to generate the artificial horizon.
regarding the procedure of complementary filters for mixing Gyro and accelerometer, I see no way that prevents the spurious signals produced by the accelerations in typical flight.
In http://www.kerhuel.eu/wiki/Image:IMU_Si ... Filter.png
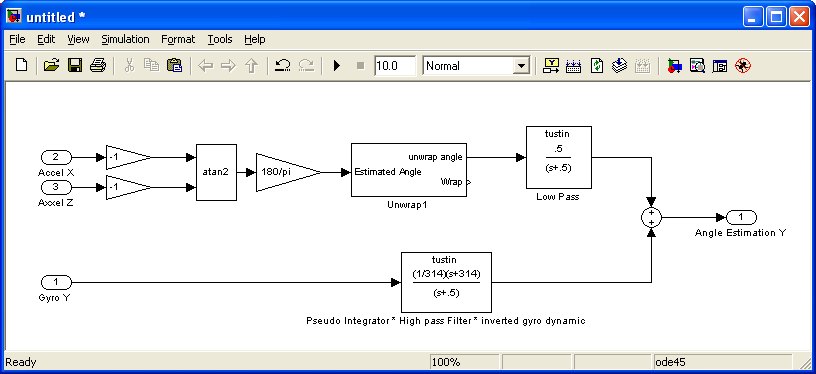
I can see that an input acceleration will produce a change in the angle output.
I'm correct..?
Re: IMU Complementary filter method
That's correct, but acceleration here is not the true acceleration of the IMU itself, but a change in the gravity vector orientation to which the accelerometer is sensitive.
Not G accelerations
hi,
I have done by now: a 3-axis accelerometer MMA7260 read by a 12-bit Coldfire MCF52233 sampled at 500 Hz.
noise filtering of vibrations do it by calculating the average value of the n-axis and then subtracting it to the n-axis.
each n-axis average value is filtered by a 9 tap Hamming LP FIR.
the result is excellent a clean g axis.
for now and for testing it is applied to the .net artificial horizon form Tom Pycke (tom.pycke.be.)
now incorporate a Gyro signal on x-axis (esky disassembly MA745/3) in a complementary filter configuration.
but not G accelerations still produce erroneous angle indication.??
sorry for my english.
I have done by now: a 3-axis accelerometer MMA7260 read by a 12-bit Coldfire MCF52233 sampled at 500 Hz.
noise filtering of vibrations do it by calculating the average value of the n-axis and then subtracting it to the n-axis.
each n-axis average value is filtered by a 9 tap Hamming LP FIR.
the result is excellent a clean g axis.
for now and for testing it is applied to the .net artificial horizon form Tom Pycke (tom.pycke.be.)
now incorporate a Gyro signal on x-axis (esky disassembly MA745/3) in a complementary filter configuration.
but not G accelerations still produce erroneous angle indication.??
sorry for my english.
Re: IMU Complementary filter method
Hi Martin,
I did not get your question. It would be helpfull to add a quick draw with transfert functions (or a simulink model)
Lubin
I did not get your question. It would be helpfull to add a quick draw with transfert functions (or a simulink model)
Lubin